Two drive approaches can both work, yet impose very different integration and service responsibilities. In a bench-top positioning fixture, the primary question is how to compare coaxial torque density with simpler parallel-axis options. The analysis is arranged around actual coaxial layout, required output torque and noise performance observations and dimensionally comparable drive candidates. Without that context, gear architecture is selected by generic efficiency slogans can remain hidden until commissioning.
01. Look at the mechanical layout
A planetary arrangement commonly keeps input and output coaxial, whereas spur trains often offset shafts; the available envelope may decide the choice. The first calculation belongs to the machine rather than the motor. On the bench-top positioning fixture, locate the output load and describe its path through the coupling or shaft. Take account of startup and stopping as separate events. Then prepare a requirement sheet that explains what it means to compare coaxial torque density with simpler parallel-axis options; keep assumptions distinct from measured mechanical demands.
02. Consider how loads share across teeth
Several planets can transmit load in parallel in a well-designed system, but actual load sharing depends on manufacturing and support accuracy. A useful engineering test captures load torque, support reaction and operating speed at the point where the requirement is applied. Use a torque instrument or a documented force-and-radius calculation and describe where the instrument is located. The bench-top positioning fixture should be tested with its normal load attached. If a measured value differs from the initial calculation, reconcile the load model before treating that difference as a motor defect.
03. Compare gearbox stages and ratio
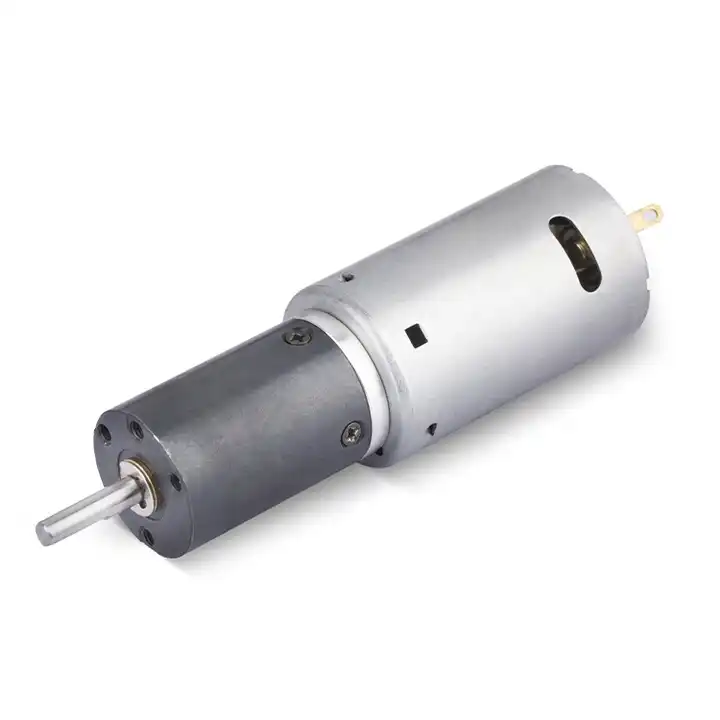
Specific reductions, losses and length depend on each gearhead design; neither architecture wins on every numerical specification. Translate the result into an output-side requirement for the bench-top positioning fixture. A motor power figure, reduction ratio and shaft-load rating describe different things; none can replace the others. The operating load also depends on the mechanism and alignment. Check the selection against dimensionally comparable drive candidates and keep any unconfirmed value out of the approved production specification.
04. Specify backlash and positioning need
An inexpensive standard planetary may have more lost motion than a precision spur option; rely on measured catalogue classes, not labels. The practical question is what the bench-top positioning fixture asks the shaft to do during its hardest normal event. Capture the timing of starts and reversals and measure whether the current limit intervenes as intended. Review the failure condition in which gear architecture is selected by generic efficiency slogans. A rated peak is meaningful only together with its allowed duration and the exact assembly to which it applies.
05. Evaluate cost and procurement flexibility
Shaft, flange and internal gear components influence tooling and lead time; compare complete geared assemblies rather than gearbox unit cost alone. Before the bench-top positioning fixture is assembled permanently, confirm tolerances and load support at its driven end. Fastening a motor securely does not guarantee that the rotating parts are coaxial. Examine the pilot, shaft fit and any pulley or lever arm, then record baseline current and sound before and after connection. This separates assembly-induced friction from component behavior.
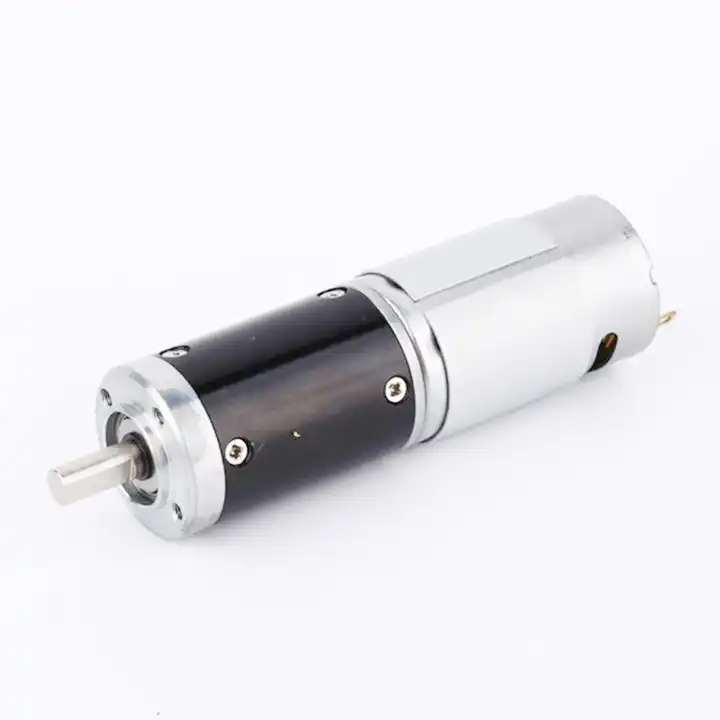
The design topic Evaluate cost and procurement flexibility also raises a question about the reduction unit used with the bench-top positioning fixture. For an overview of alternative arrangements, explore planetary gearbox design options. Reducer-only information must still be checked against the motor, driver and exact gearbox configuration considered for this application.
06. Assess noise by test
Gear mesh frequency and housing resonance vary with speed, tooth form and installation; a useful comparison uses equivalent load and measurement conditions. For the bench-top positioning fixture, write an acceptance procedure that can be run again after a design revision. The procedure should log speed-dependent sound, reversal play and mechanical alignment, measured through a controlled speed sweep and a repeatable lash or vibration measurement, together with software and wiring configuration. Observe both cold startup and a representative warm operating condition. Keep the outcome connected to the exact tested gearbox and motor revision.
07. Check radial-load path
Both spur and planetary outputs need bearing limits verified when driving a pulley or wheel directly. Define the conditions that require the bench-top positioning fixture test to stop. A finding of a shaft load or transient torque outside the approved envelope should trigger a check of shaft support, wiring and the commanded motion profile. Keep the duty and environment unchanged while testing one possible cause at a time. This protects the unit and produces evidence that is useful for engineering or supplier follow-up.
- Confirm the measurement basis for check radial-load path, including instrument location and units.
- Record the normal and limiting operating states of the bench-top positioning fixture.
- Compare the observed coaxial layout, required output torque and noise performance with verified assembly documentation before approving this configuration.
08. Run a decision matrix
Weight torque, available space, control resolution, durability and total installed cost according to the actual machine requirement. Finish with a decision that can be checked on the bench-top positioning fixture. The selected assembly must compare coaxial torque density with simpler parallel-axis options with the intended supply, installed load and duty pattern. Keep the approved interface drawing and dimensionally comparable drive candidates alongside the test results. If a future machine revision alters those conditions, requalify the motor-and-reducer combination rather than assuming the earlier approval still applies.
09. Numerical screening for bench-top positioning fixture
For illustration, imagine the bench-top positioning fixture under its design load. Imagine the selected mechanism repeats a four-second movement followed by a six-second dwell. A basic test can log output displacement, peak current and housing temperature for each ten-second cycle. This example defines a test method, not a product performance claim. The important conclusion is not one output number but which portion of coaxial layout, required output torque and noise performance has been measured. Test the resulting drive against dimensionally comparable drive candidates when aiming to compare coaxial torque density with simpler parallel-axis options.
10. Verification procedure: coaxial layout, required output torque and noise performance
Build a controlled test around bench-top positioning fixture. Inspect the shaft, pilot and electrical leads before coupling the load, and log coaxial layout, required output torque and noise performance during the operating event. With the final mechanism attached, compare results with dimensionally comparable drive candidates. An indication that gear architecture is selected by generic efficiency slogans calls for stopping the trial and identifying which component sets the limit.
| Engineering checkpoint | Observation for bench-top positioning fixture | Approval implication |
|---|---|---|
| Machine duty | coaxial layout, required output torque and noise performance | Keep the measured conditions of bench-top positioning fixture comparable |
| Output interface | Mounting and wiring of the bench-top positioning fixture | Check evaluate cost and procurement flexibility against the drawing |
| Evidence basis | dimensionally comparable drive candidates | Confirms compare coaxial torque density with simpler parallel-axis options |
| Escalation trigger | gear architecture is selected by generic efficiency slogans | Stop for review if the bench-top positioning fixture behaves outside limits |
11. What to specify when quoting this comparison task
A comparable quote for bench-top positioning fixture requires more than voltage and nominal ratio. Provide the physical interface drawing, motion duty and the measurable target: compare coaxial torque density with simpler parallel-axis options. Ask each supplier to respond to coaxial layout, required output torque and noise performance and identify the exact test or catalogue basis for dimensionally comparable drive candidates.
- State the device and target: bench-top positioning fixture; compare coaxial torque density with simpler parallel-axis options.
- Include locating pilot, shaft and flange tolerances for the bench-top positioning fixture installation.
- Identify voltage and feedback needed for the bench-top positioning fixture, including motor-driver protections.
- Connect coaxial layout, required output torque and noise performance to peak and continuous load cases and relevant cycle timing.
- Record installation constraints for the bench-top positioning fixture and the planned acceptance method.
- Confirm dimensionally comparable drive candidates before release of the exact motor-reducer option.
12. Release decision for bench-top positioning fixture
Maintain a short history of accepted and rejected drive arrangements for bench-top positioning fixture. File measured coaxial layout, required output torque and noise performance beside dimensionally comparable drive candidates; include the reason a candidate could or could not compare coaxial torque density with simpler parallel-axis options. This makes the failure scenario that gear architecture is selected by generic efficiency slogans visible when later production batches arrive.
Questions raised by bench-top positioning fixture applications
Why is look at the mechanical layout important for this application?
A planetary arrangement commonly keeps input and output coaxial, whereas spur trains often offset shafts; the available envelope may decide the choice. In the bench-top positioning fixture, the review should link that condition to coaxial layout, required output torque and noise performance before a motor is selected.
What mistake should be avoided when considering specify backlash and positioning need?
An inexpensive standard planetary may have more lost motion than a precision spur option; rely on measured catalogue classes, not labels. A failure to document the issue may lead to the situation where gear architecture is selected by generic efficiency slogans.
How should check radial-load path be checked?
Both spur and planetary outputs need bearing limits verified when driving a pulley or wheel directly. Collect evidence during the intended movement of the bench-top positioning fixture, not only while the output runs freely.
What records verify the bench-top positioning fixture drive configuration?
Provide the machine drawing, motor control requirements, coaxial layout, required output torque and noise performance and dimensionally comparable drive candidates. Explain the application goal: compare coaxial torque density with simpler parallel-axis options.
To discuss compare coaxial torque density with simpler parallel-axis options on a bench-top positioning fixture, send the measurement summary and interface drawing to satış@planetarymotors.top. Include the coaxial layout, required output torque and noise performance so the motor and reduction unit can be assessed together.