Engineering acceptance depends on the way a number is defined and measured, not only on its printed magnitude. Consider a battery-operated locking mechanism that must separate expected startup current from dangerous blocked-output operation. Its motor and reduction unit must be treated together with the supporting hardware and controller. The risk that stall torque is relied on as routine holding torque frames the checks in this article; locked-rotor current, startup duration and controller protection threshold are part of the necessary evidence.
01. Understand the startup transient
At very low speed, motor back EMF is small and winding current can rise rapidly depending on the controller and supply resistance. Treat the mechanism as a sequence of states, not a single rated speed. With the battery-operated locking mechanism, list the driven load, resistance at rest, available travel, and any gravity or process force. A suitable planetary gearmotor must serve the complete sequence. Only after that description is agreed should the target to separate expected startup current from dangerous blocked-output operation be translated into electrical and mechanical specifications.
02. Measure current with the correct instrument
An averaged multimeter may miss a short peak; use a current probe or suitable data logger for startup waveforms. Set up one repeatable operating point on the battery-operated locking mechanism. Record the applied load and supply conditions, then collect terminal voltage, current waveform and controller state. The practical measurement method is a current probe and a logged supply-voltage channel; retain a trace rather than only a pass/fail statement. This distinguishes a controller limit from resistance in the attached mechanism and makes later comparisons between candidates meaningful.

03. Limit both magnitude and duration
A controller should restrict damaging current and detect persistent no-motion conditions rather than repeating high-energy attempts. Use the measured output of the battery-operated locking mechanism to challenge the proposed drive choice. Calculate the needed motion, account for efficiency where specified and check the physical shaft reaction. The objective to separate expected startup current from dangerous blocked-output operation can be achieved only if the motor, reduction unit and controller each remain inside their individual ratings. Confirm those boundaries using controlled obstacle and stall detection trial.
04. Protect mechanical transmission parts
The gearhead may have a lower safe peak torque than the motor can produce at electrical stall; gear tooth and coupling strength still govern. A successful single start does not validate a production cycle for the battery-operated locking mechanism. Record the peak load, the length of the event and the interval before it recurs. The design review must specifically address the possibility that stall torque is relied on as routine holding torque. A protected repeat-cycle trial is more informative than repeating one unloaded startup.
05. Recognize the mechanical root cause
A jammed slide, frozen seal or misaligned shaft can appear electrically as an overcurrent condition. Mechanical integration is a separate qualification item on the battery-operated locking mechanism. Verify mounting pilot, flange seating, output-shaft support and strain relief before testing full load. A side load on the output bearing or an unaligned rigid coupling can change current and sound without any fault inside the motor. Inspect the final assembly drawing rather than relying on a catalog photograph.
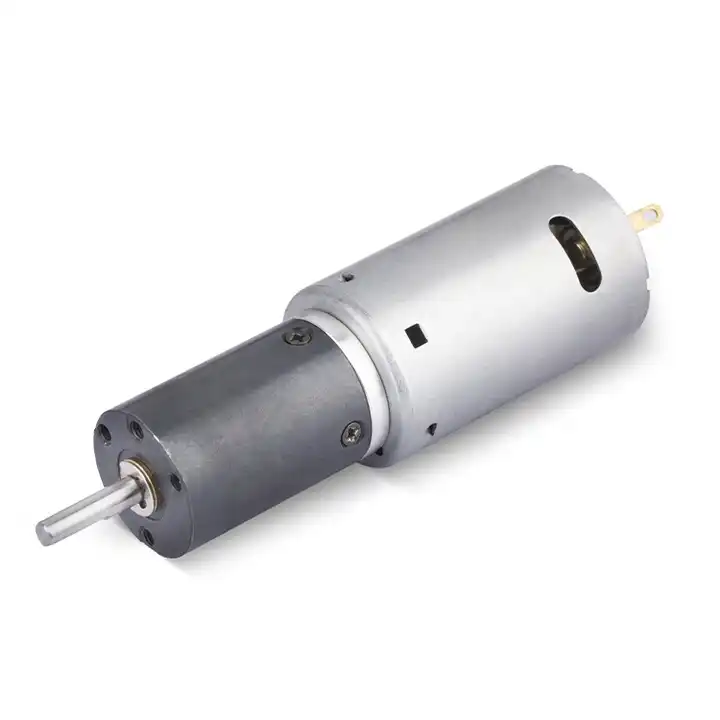
The design topic Recognize the mechanical root cause also raises a question about the reduction unit used with the battery-operated locking mechanism. For an overview of alternative arrangements, explore industrial planetary gear reduction. Reducer-only information must still be checked against the motor, driver and exact gearbox configuration considered for this application.
06. Design a fault response
Decide whether the mechanism releases, stops, retries once or alerts an operator; safety requirements determine allowed behavior. The test record should explain what was connected and what was commanded on the battery-operated locking mechanism. Instrument requested duty, mechanical clearance and operating condition using a controlled fixture and a signed dimensional inspection, then compare repeated trials at equivalent load and environmental conditions. If the reading drifts, investigate heat, drag and controller settings before selecting a replacement component. A reproducible result is worth more than an optimistic peak figure.
07. Account for supply sag
A battery or cable that droops at startup may cause controller reset even when gearmotor torque is adequate in theory. When the battery-operated locking mechanism shows signs of an undocumented assumption at the mechanical interface, investigate before escalating the motor rating. Check whether the applied load, controller protection or shaft alignment has changed. One controlled change at a time reveals the likely cause more reliably than replacing several parts together. The engineering record should preserve the first abnormal measurement and the corrective action.
- Confirm the measurement basis for account for supply sag, including instrument location and units.
- Record the normal and limiting operating states of the battery-operated locking mechanism.
- Compare the observed locked-rotor current, startup duration and controller protection threshold with verified assembly documentation before approving this configuration.
08. Perform a bounded blocked-output test
Use an approved safe test fixture and current-limited driver; never intentionally force a production mechanism beyond its rated load. The final output is a measurable acceptance criterion for the battery-operated locking mechanism, not just a catalog selection. Confirm that the drive can separate expected startup current from dangerous blocked-output operation during the complete intended cycle. Document the exact hardware revision, installation method and controlled obstacle and stall detection trial. This allows an incoming unit or later design change to be assessed on the same technical basis.
09. Numerical screening for battery-operated locking mechanism
For illustration, imagine the battery-operated locking mechanism under its design load. Imagine a gearmotor that draws 0.6 A during free running but exhibits a 4 A short startup pulse in a current-limited fixture. Those are deliberately hypothetical readings: record the actual trace and evaluate pulse duration before specifying the driver. The important conclusion is not one output number but which portion of locked-rotor current, startup duration and controller protection threshold has been measured. Test the resulting drive against controlled obstacle and stall detection trial when aiming to separate expected startup current from dangerous blocked-output operation.
10. Verification procedure: locked-rotor current, startup duration and controller protection threshold
Build a controlled test around battery-operated locking mechanism. Inspect the shaft, pilot and electrical leads before coupling the load, and log locked-rotor current, startup duration and controller protection threshold during the operating event. With the final mechanism attached, compare results with controlled obstacle and stall detection trial. An indication that stall torque is relied on as routine holding torque calls for stopping the trial and identifying which component sets the limit.
| Engineering checkpoint | Observation for battery-operated locking mechanism | Approval implication |
|---|---|---|
| Machine duty | locked-rotor current, startup duration and controller protection threshold | Keep the measured conditions of battery-operated locking mechanism comparable |
| Output interface | Mounting and wiring of the battery-operated locking mechanism | Check recognize the mechanical root cause against the drawing |
| Evidence basis | controlled obstacle and stall detection trial | Confirms separate expected startup current from dangerous blocked-output operation |
| Escalation trigger | stall torque is relied on as routine holding torque | Stop for review if the battery-operated locking mechanism behaves outside limits |
11. What to specify when quoting this engineering task
A comparable quote for battery-operated locking mechanism requires more than voltage and nominal ratio. Provide the physical interface drawing, motion duty and the measurable target: separate expected startup current from dangerous blocked-output operation. Ask each supplier to respond to locked-rotor current, startup duration and controller protection threshold and identify the exact test or catalogue basis for controlled obstacle and stall detection trial.
- State the device and target: battery-operated locking mechanism; separate expected startup current from dangerous blocked-output operation.
- Include locating pilot, shaft and flange tolerances for the battery-operated locking mechanism installation.
- Identify voltage and feedback needed for the battery-operated locking mechanism, including motor-driver protections.
- Connect locked-rotor current, startup duration and controller protection threshold to peak and continuous load cases and relevant cycle timing.
- Record installation constraints for the battery-operated locking mechanism and the planned acceptance method.
- Confirm controlled obstacle and stall detection trial before release of the exact motor-reducer option.
12. Release decision for battery-operated locking mechanism
Maintain a short history of accepted and rejected drive arrangements for battery-operated locking mechanism. File measured locked-rotor current, startup duration and controller protection threshold beside controlled obstacle and stall detection trial; include the reason a candidate could or could not separate expected startup current from dangerous blocked-output operation. This makes the failure scenario that stall torque is relied on as routine holding torque visible when later production batches arrive.
Questions raised by battery-operated locking mechanism applications
Why is understand the startup transient important for this application?
At very low speed, motor back EMF is small and winding current can rise rapidly depending on the controller and supply resistance. In the battery-operated locking mechanism, the review should link that condition to locked-rotor current, startup duration and controller protection threshold before a motor is selected.
What mistake should be avoided when considering protect mechanical transmission parts?
The gearhead may have a lower safe peak torque than the motor can produce at electrical stall; gear tooth and coupling strength still govern. A failure to document the issue may lead to the situation where stall torque is relied on as routine holding torque.
How should account for supply sag be checked?
A battery or cable that droops at startup may cause controller reset even when gearmotor torque is adequate in theory. Collect evidence during the intended movement of the battery-operated locking mechanism, not only while the output runs freely.
What records verify the battery-operated locking mechanism drive configuration?
Provide the machine drawing, motor control requirements, locked-rotor current, startup duration and controller protection threshold and controlled obstacle and stall detection trial. Explain the application goal: separate expected startup current from dangerous blocked-output operation.
To discuss separate expected startup current from dangerous blocked-output operation on a battery-operated locking mechanism, send the measurement summary and interface drawing to [email protected]. Include the locked-rotor current, startup duration and controller protection threshold so the motor and reduction unit can be assessed together.